ECE Colloquium: Timothy Barfoot (Toronto)
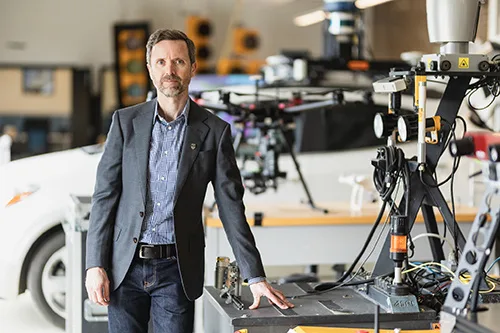
Local Maps Are All You Need
In robotics, we have spent a lot of time building really good maps from noisy sensor data. Who doesn’t like a nice, crisp, globally consistent map? Over the last 20 years, I have been exploring a paradigm to robot navigation that eschews such globally consistent maps in favor of graphs of local maps, which are cheaper to construct, store, and query. These topometric maps enable so-called teach-and-repeat (T&R) navigation. In this talk, I will give a progress update on some of the new things we are doing with T&R including using different primary sensors, teaching with one robot and repeating with another, repeating with multiple robots together, and enabling end-user applications such as Arctic patrol and lunar cargo transport. Hopefully, I will convince you that local maps are all you need (i.e., sufficient) for a lot of common robotics scenarios. I will also try to convince you that local maps are necessary!
Bio: Timothy Barfoot (University of Toronto Institute for Aerospace Studies – UTIAS) works in the area of autonomy for mobile robots targeting a variety of applications. He develops methods (localization, mapping, planning, control) to allow robots to operate over long periods of time in large-scale, unstructured, three-dimensional environments, using rich onboard sensing (e.g., cameras, laser rangefinders, radar) and computation.
Timothy holds a B.A.Sc. (9T6+PEY, Aerospace Option) from the University of Toronto engineering science program and a Ph.D. from UTIAS in robotics. He took up his academic position at UTIAS in May 2007, after spending four years at MDA Space (builder of the well-known Canadarm space manipulators), where he developed autonomous vehicle navigation technologies for both planetary rovers and terrestrial applications such as underground mining.
He is a Fellow of the IEEE, a Fellow of the Canadian Academy of Engineering, held a Canada Research Chair (Tier 2) for the full 10 years, was an Early Researcher Awardee in the Province of Ontario, and has received one paper award from the International Journal of Robotics Research (2026), three from the IEEE International Conference on Robotics and Automation (ICRA 2010, 2021, 2025), and four at the Conference on Robots and Vision (CRV 2014, 2016, 2023, 2025).
Timothy began serving as Director (Dept. Head) of UTIAS in July 2026, and previously served as Director of the UofT Robotics Institute, Director of the UofT Collaborative Specialization in Robotics, co-Faculty Advisor of UofT's self-driving car team that won the SAE Autodrive competition several times, Chair of the UofT Engineering Science Robotics Major, and was a Faculty Affiliate of the Vector Institute. He was a Visiting Professor at the University of Oxford (2013, 2024) and worked as Director of Autonomous Systems at Apple in California (2017-9). He holds the position of Distinguished Engineer at Oxa Autonomy Ltd (parttime).
He is the Editor in Chief of the IEEE Transactions on Field Robotics, deputy EiC of the International Journal of Robotics Research, served on the Foundation Board of Robotics: Science and Systems, and served as the General Chair of Field and Service Robotics 2015, which was held in Toronto. He is the author of State Estimation for Robotics (Cambridge 2017, 2024), which is free to download from his webpage, and co-editor/co-author of the SLAM Handbook (Cambridge 2026).
Eventos por perto
 Going to Gone: Earth's Biodiversity Loss and What We Can Do About It
Mann Library · Ithaca
 Cornell Women's Soccer vs University of Pennsylvania - Fall Fest
Berman Field · Ithaca